Hover to preview
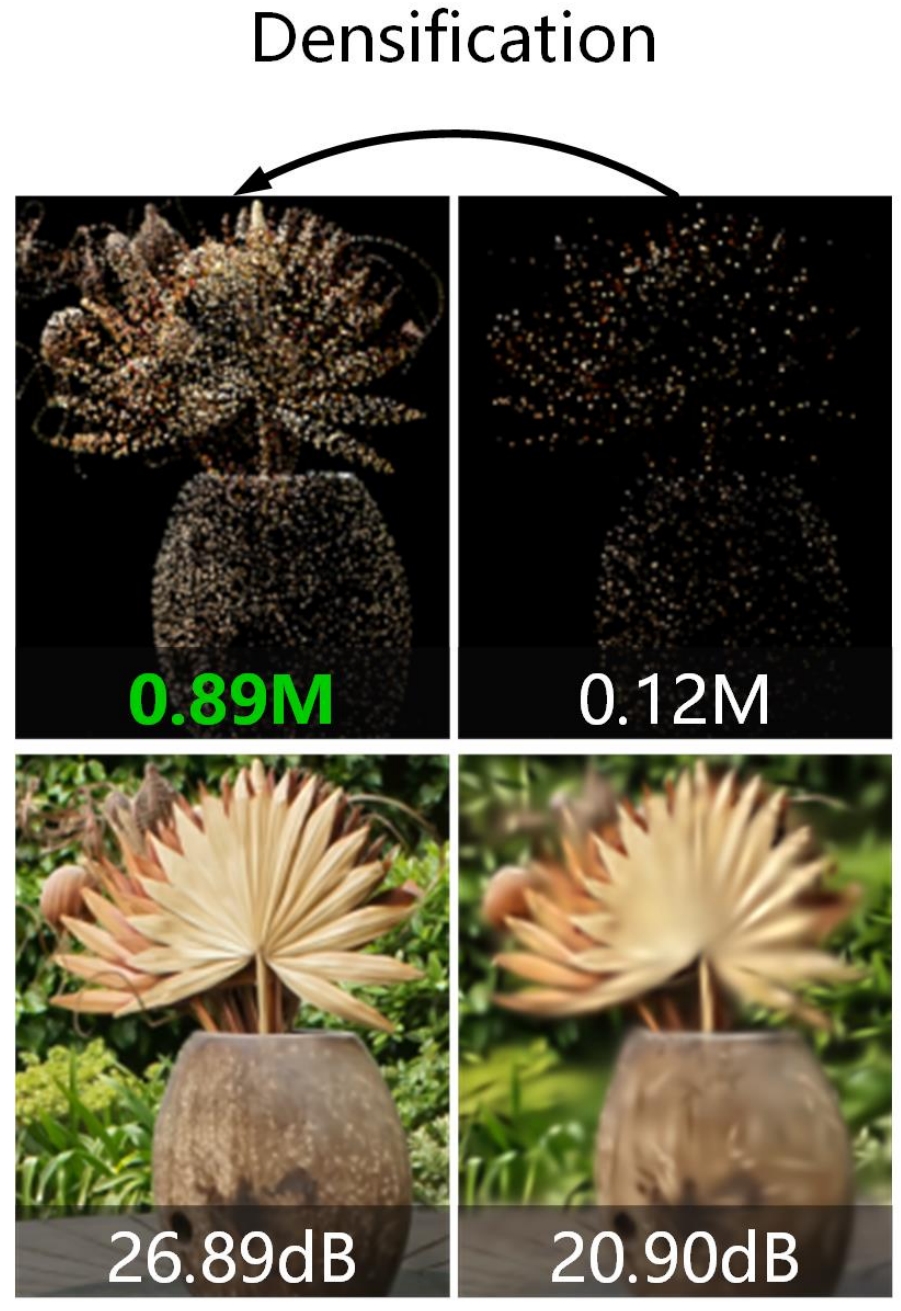
FastGS: Training 3D Gaussian Splatting in 100 Seconds
A densification strategy for fast, efficient 3D Gaussian Splatting optimization.
Research portfolio · Nankai University
Building world models and 3D reconstruction systems that connect perception, generation, and closed-loop simulation.
I am pursuing a PhD at Nankai University, advised by Prof. Yongchun Fang. Since April 2025, I have also been an intern at DJI. My goal is to make simulated worlds realistic and reliable enough for autonomous driving and embodied intelligence.
Selected work
From efficient 3D reconstruction to robust state estimation in demanding real-world environments.
Research
Publication venues and open-source impact.
Hover to preview
A densification strategy for fast, efficient 3D Gaussian Splatting optimization.
Hover to preview
Hover to preview
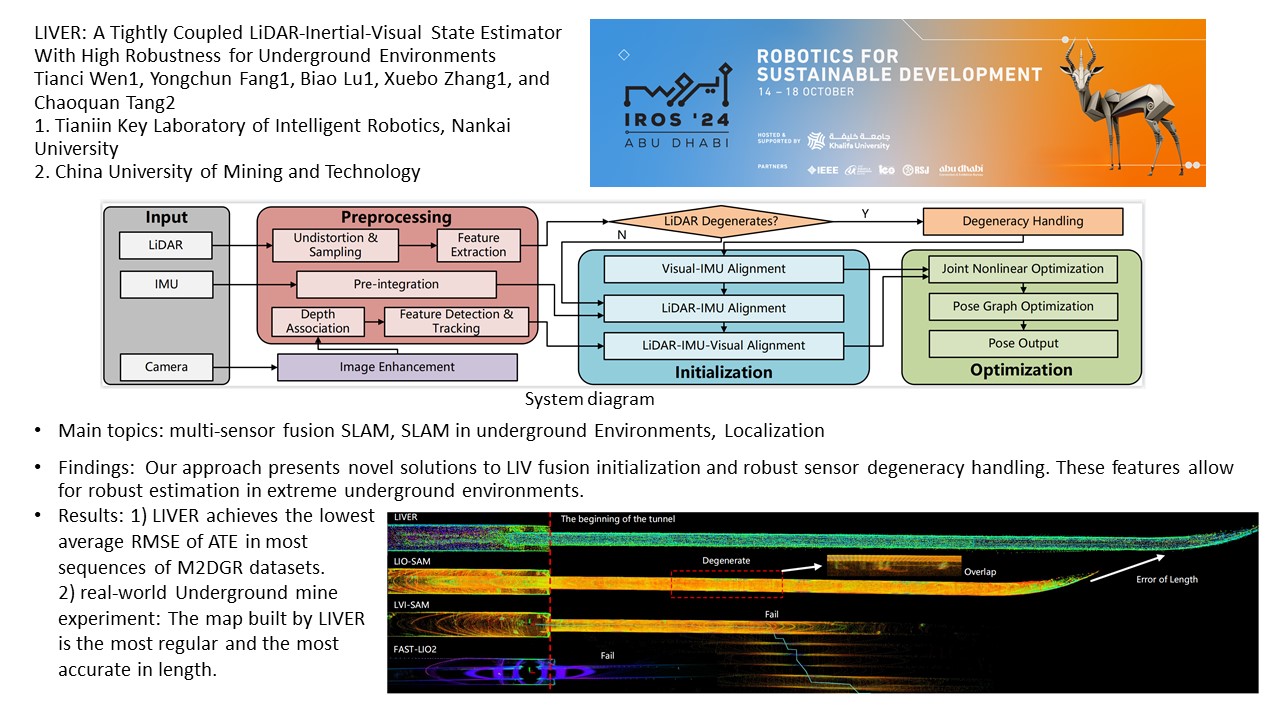
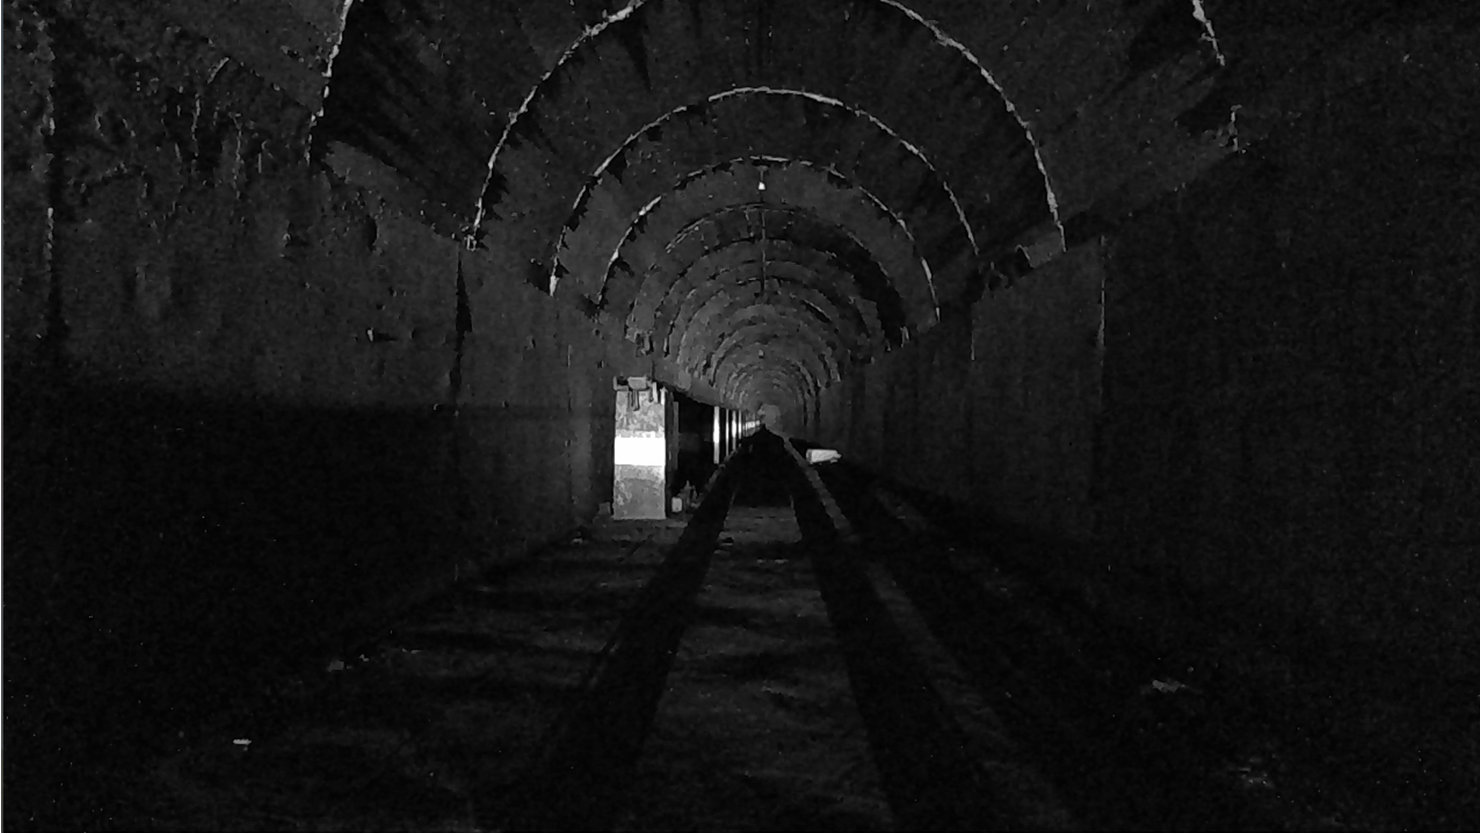
Tightly coupled multi-sensor localization and mapping for challenging underground environments.
Projects
Systems work across sensing, estimation, navigation, and industrial deployment.
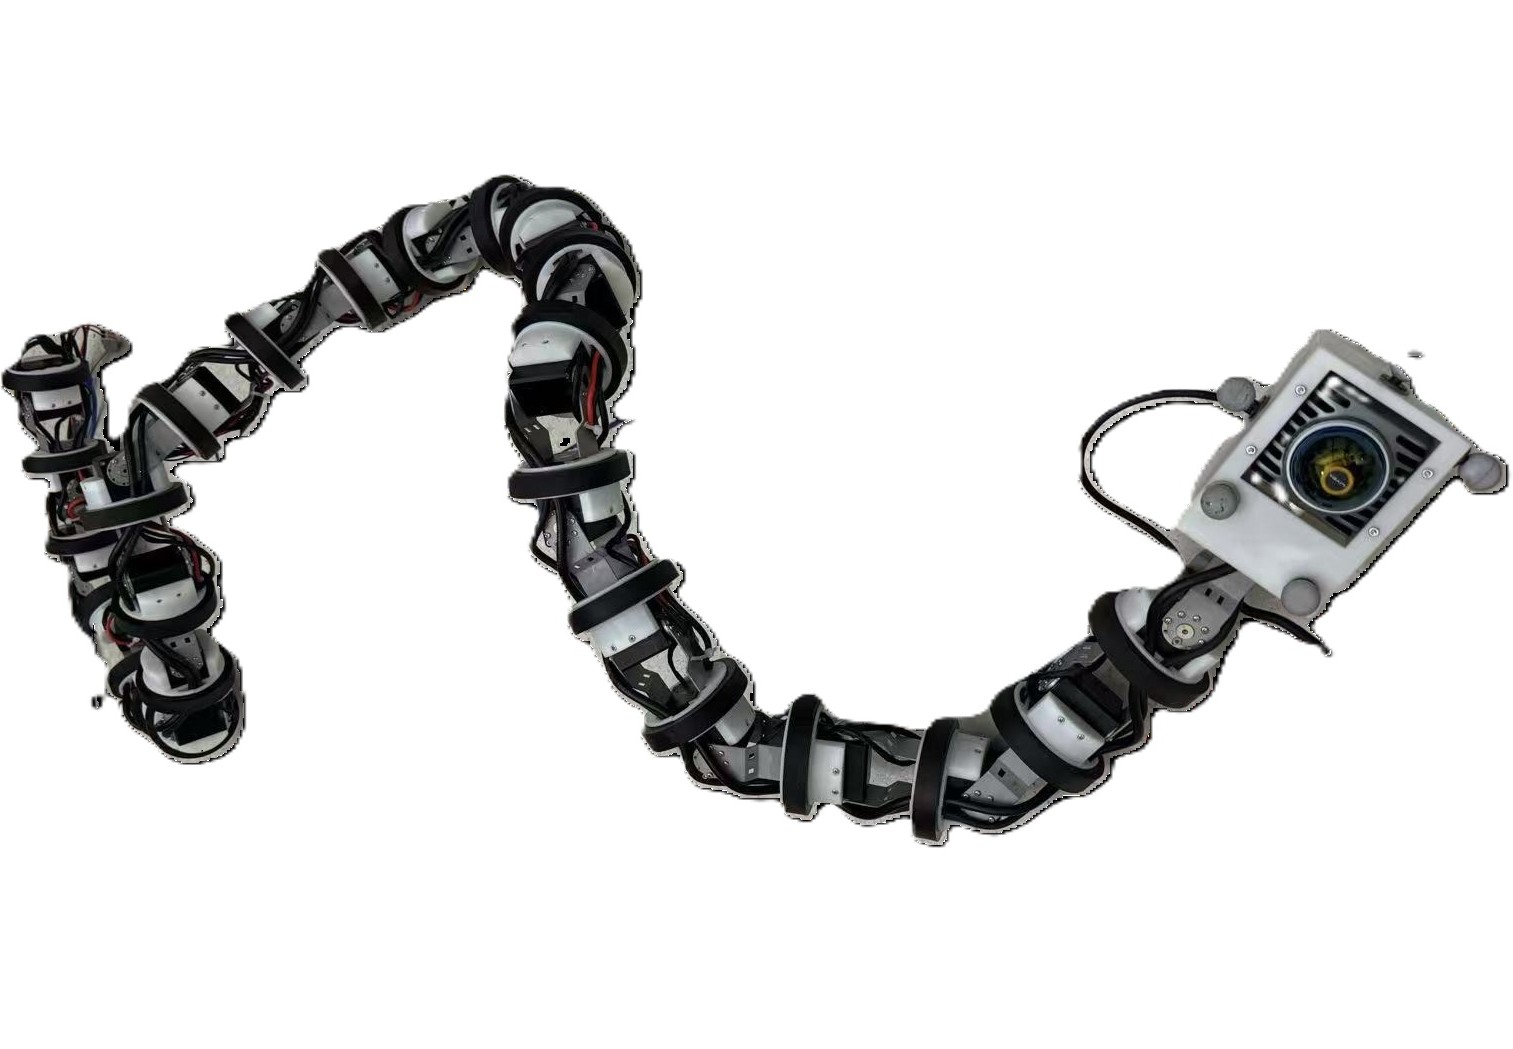
Integrated LiDAR, camera, and IMU in a compact system, achieving centimeter-level localization across multiple gaits and speeds.
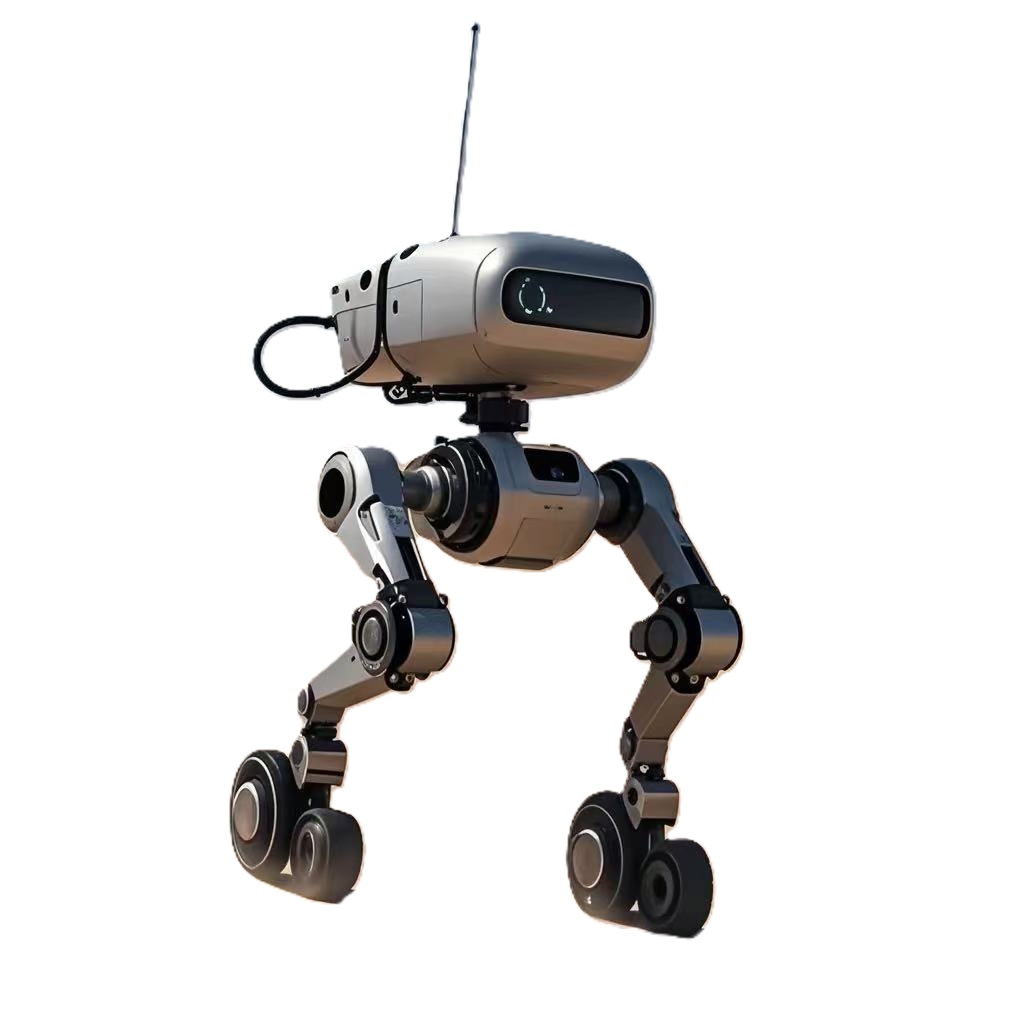
Indoor navigation built on ROS move_base and LiDAR-inertial odometry for a wheeled-leg robot.
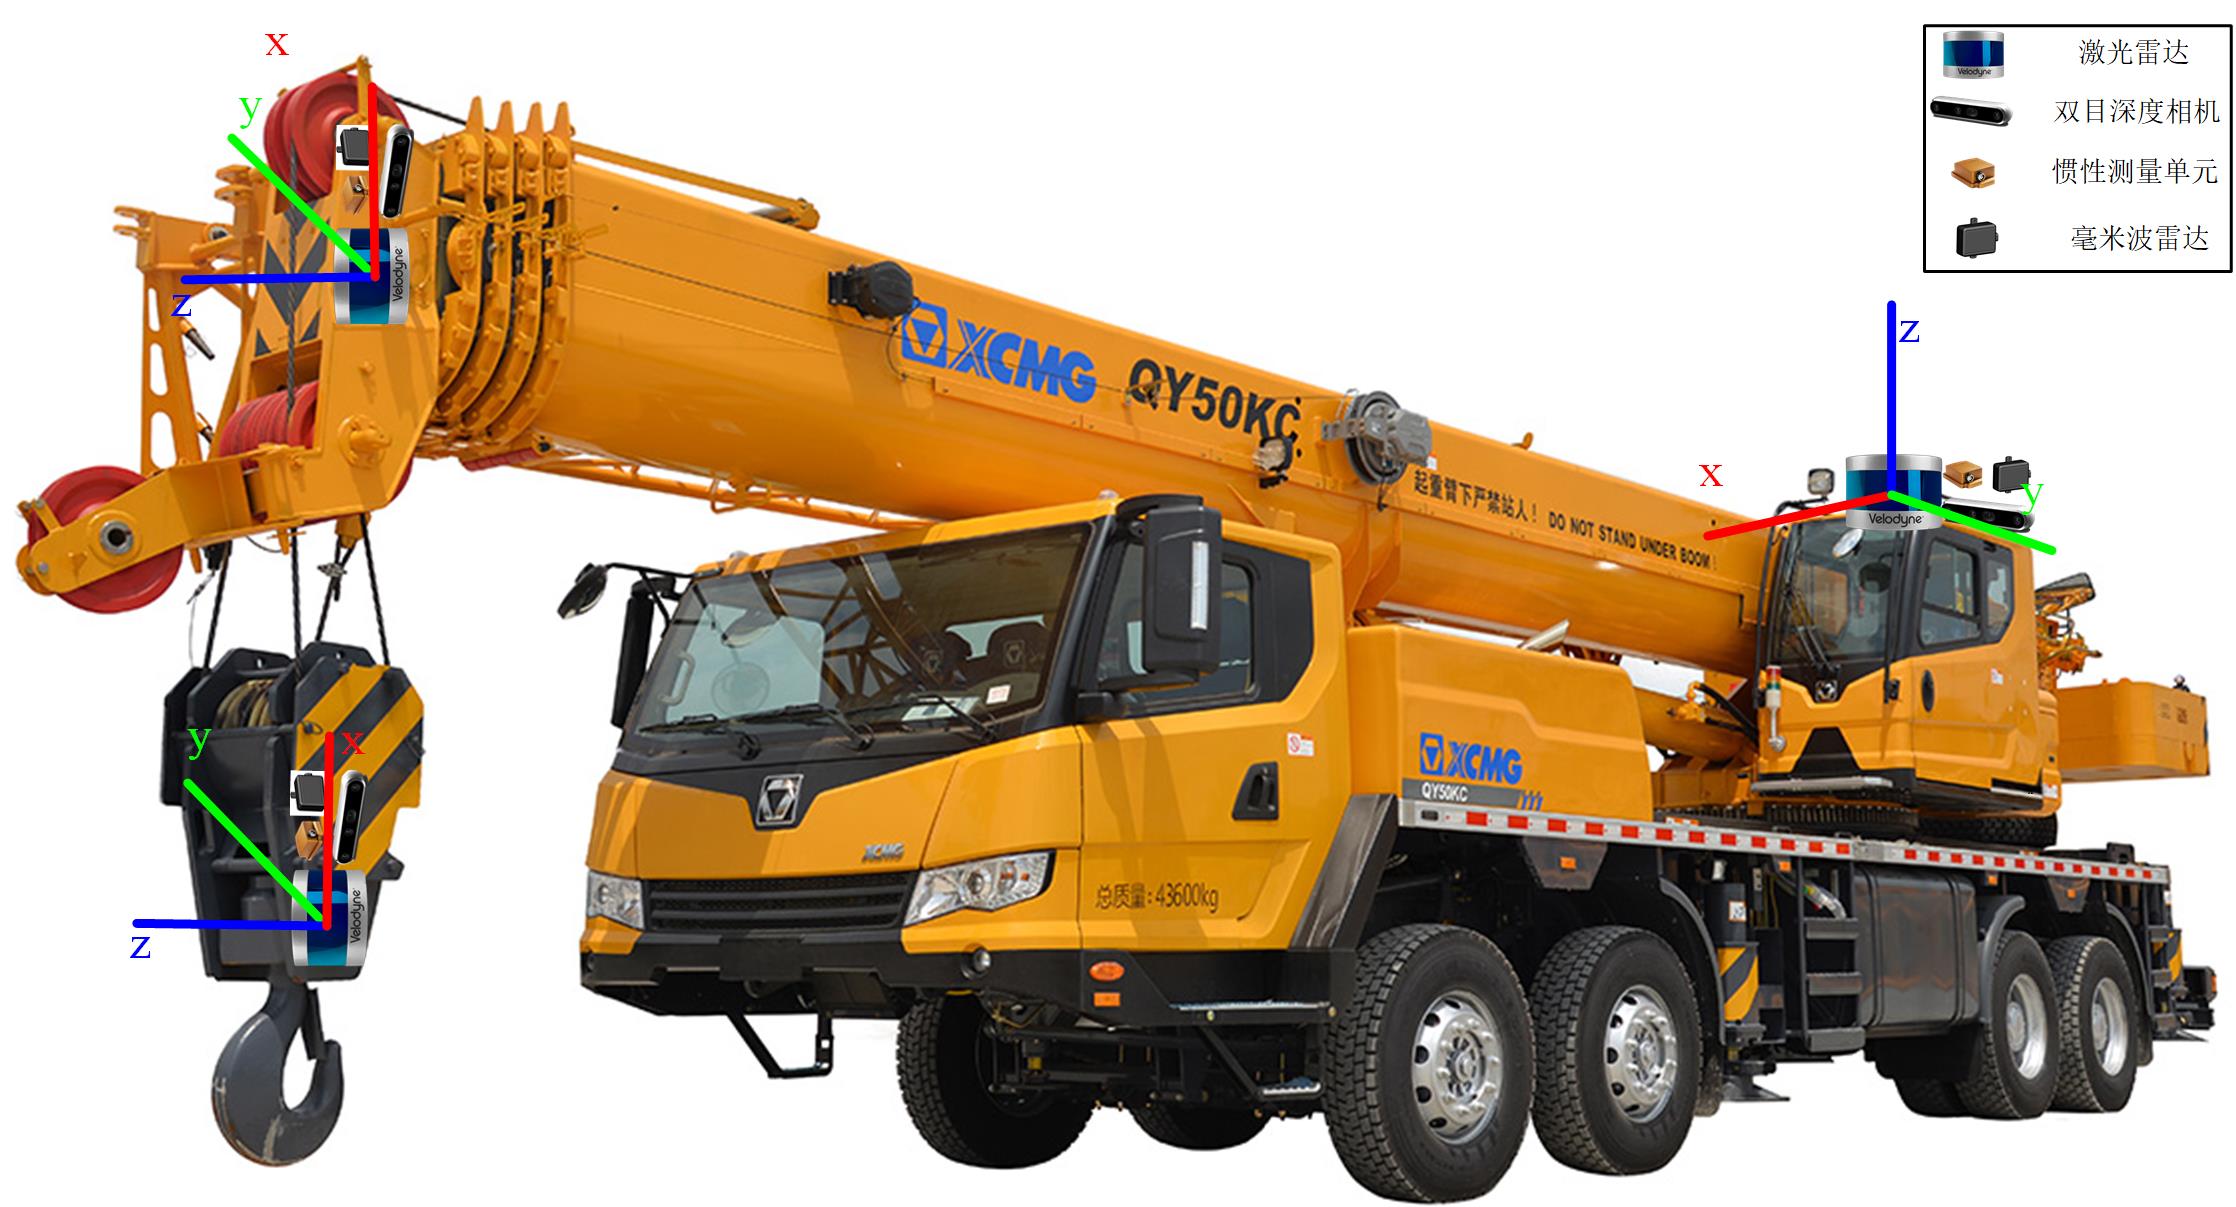
Software, hardware, and SLAM system development for a giant industrial crane.
About
My research sits between 3D vision and robotics: reconstructing scenes with high geometric fidelity, generating novel views, and evaluating whether those worlds remain useful once a policy or perception stack is placed inside them.
Nankai University · advised by Prof. Yongchun Fang
DJI · since April 2025
Jilin University
With thanks
Zhixing Song for guidance in SLAM and research, and Haiming Gao for guidance on research direction.
Earlier work in control